Project 01 / Mechatronics / 2025 / Bachelor's thesis
4WS Mobile Robot
A four-wheel-steer, four-wheel-drive robot that can drive sideways.
Read the thesis (Swedish) ↗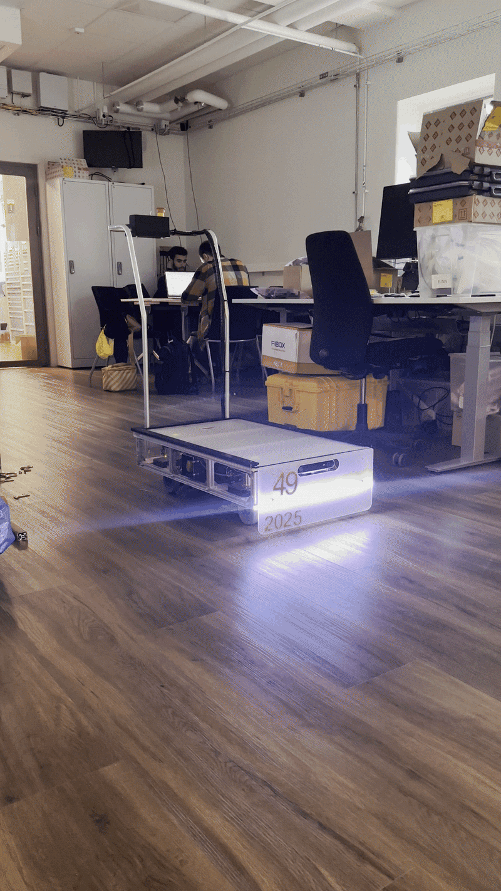
↑ Parallel parking is easy when every wheel steers
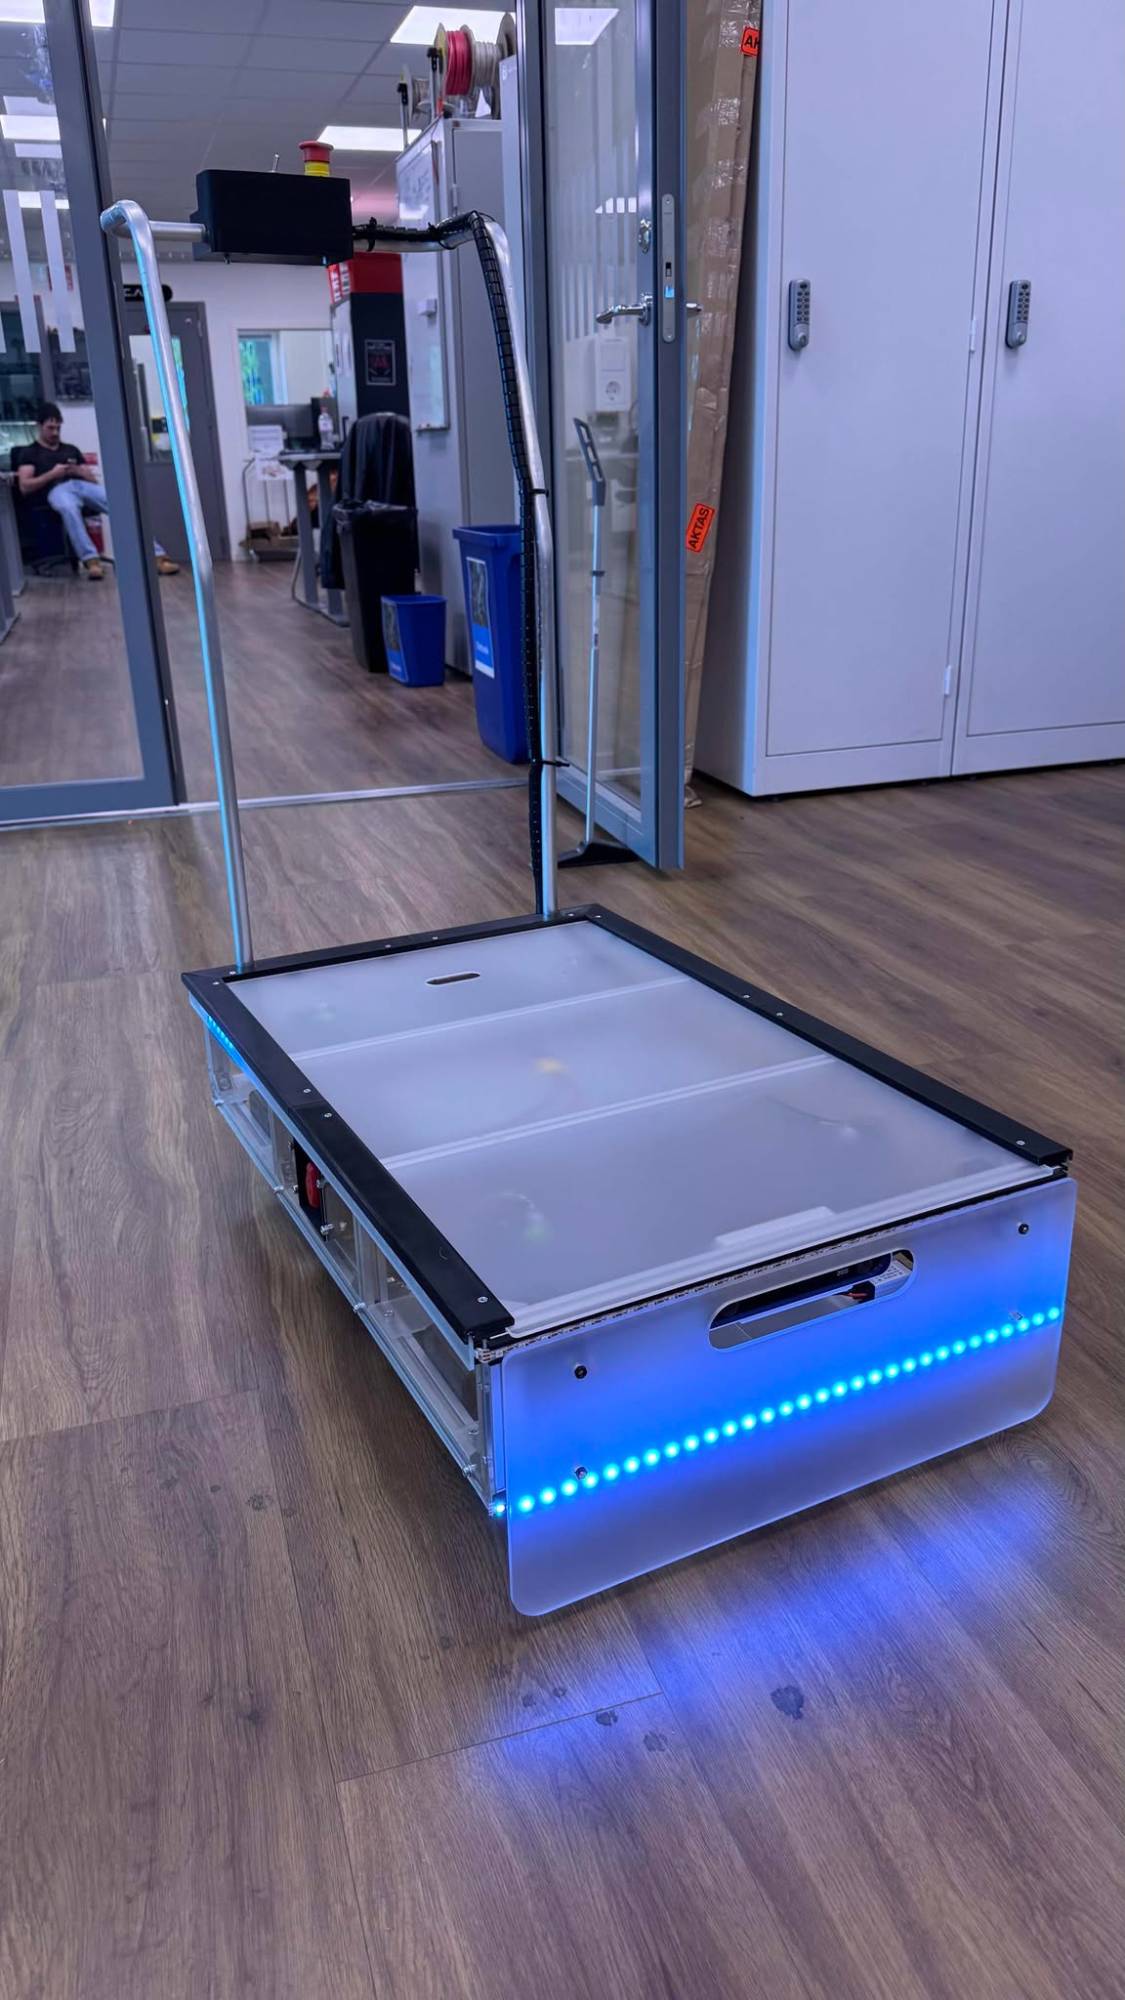
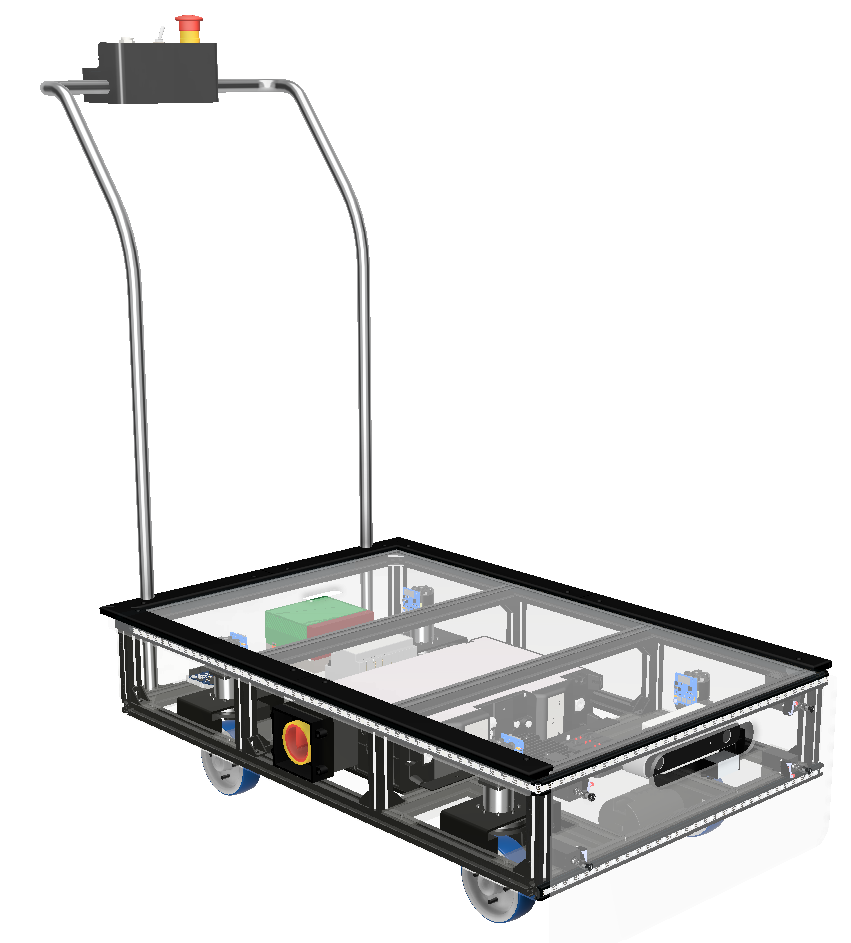 CADReal
↔ Drag to compare design and reality
In action
↑ Parallel parking in crab mode
↑ A 90° turn
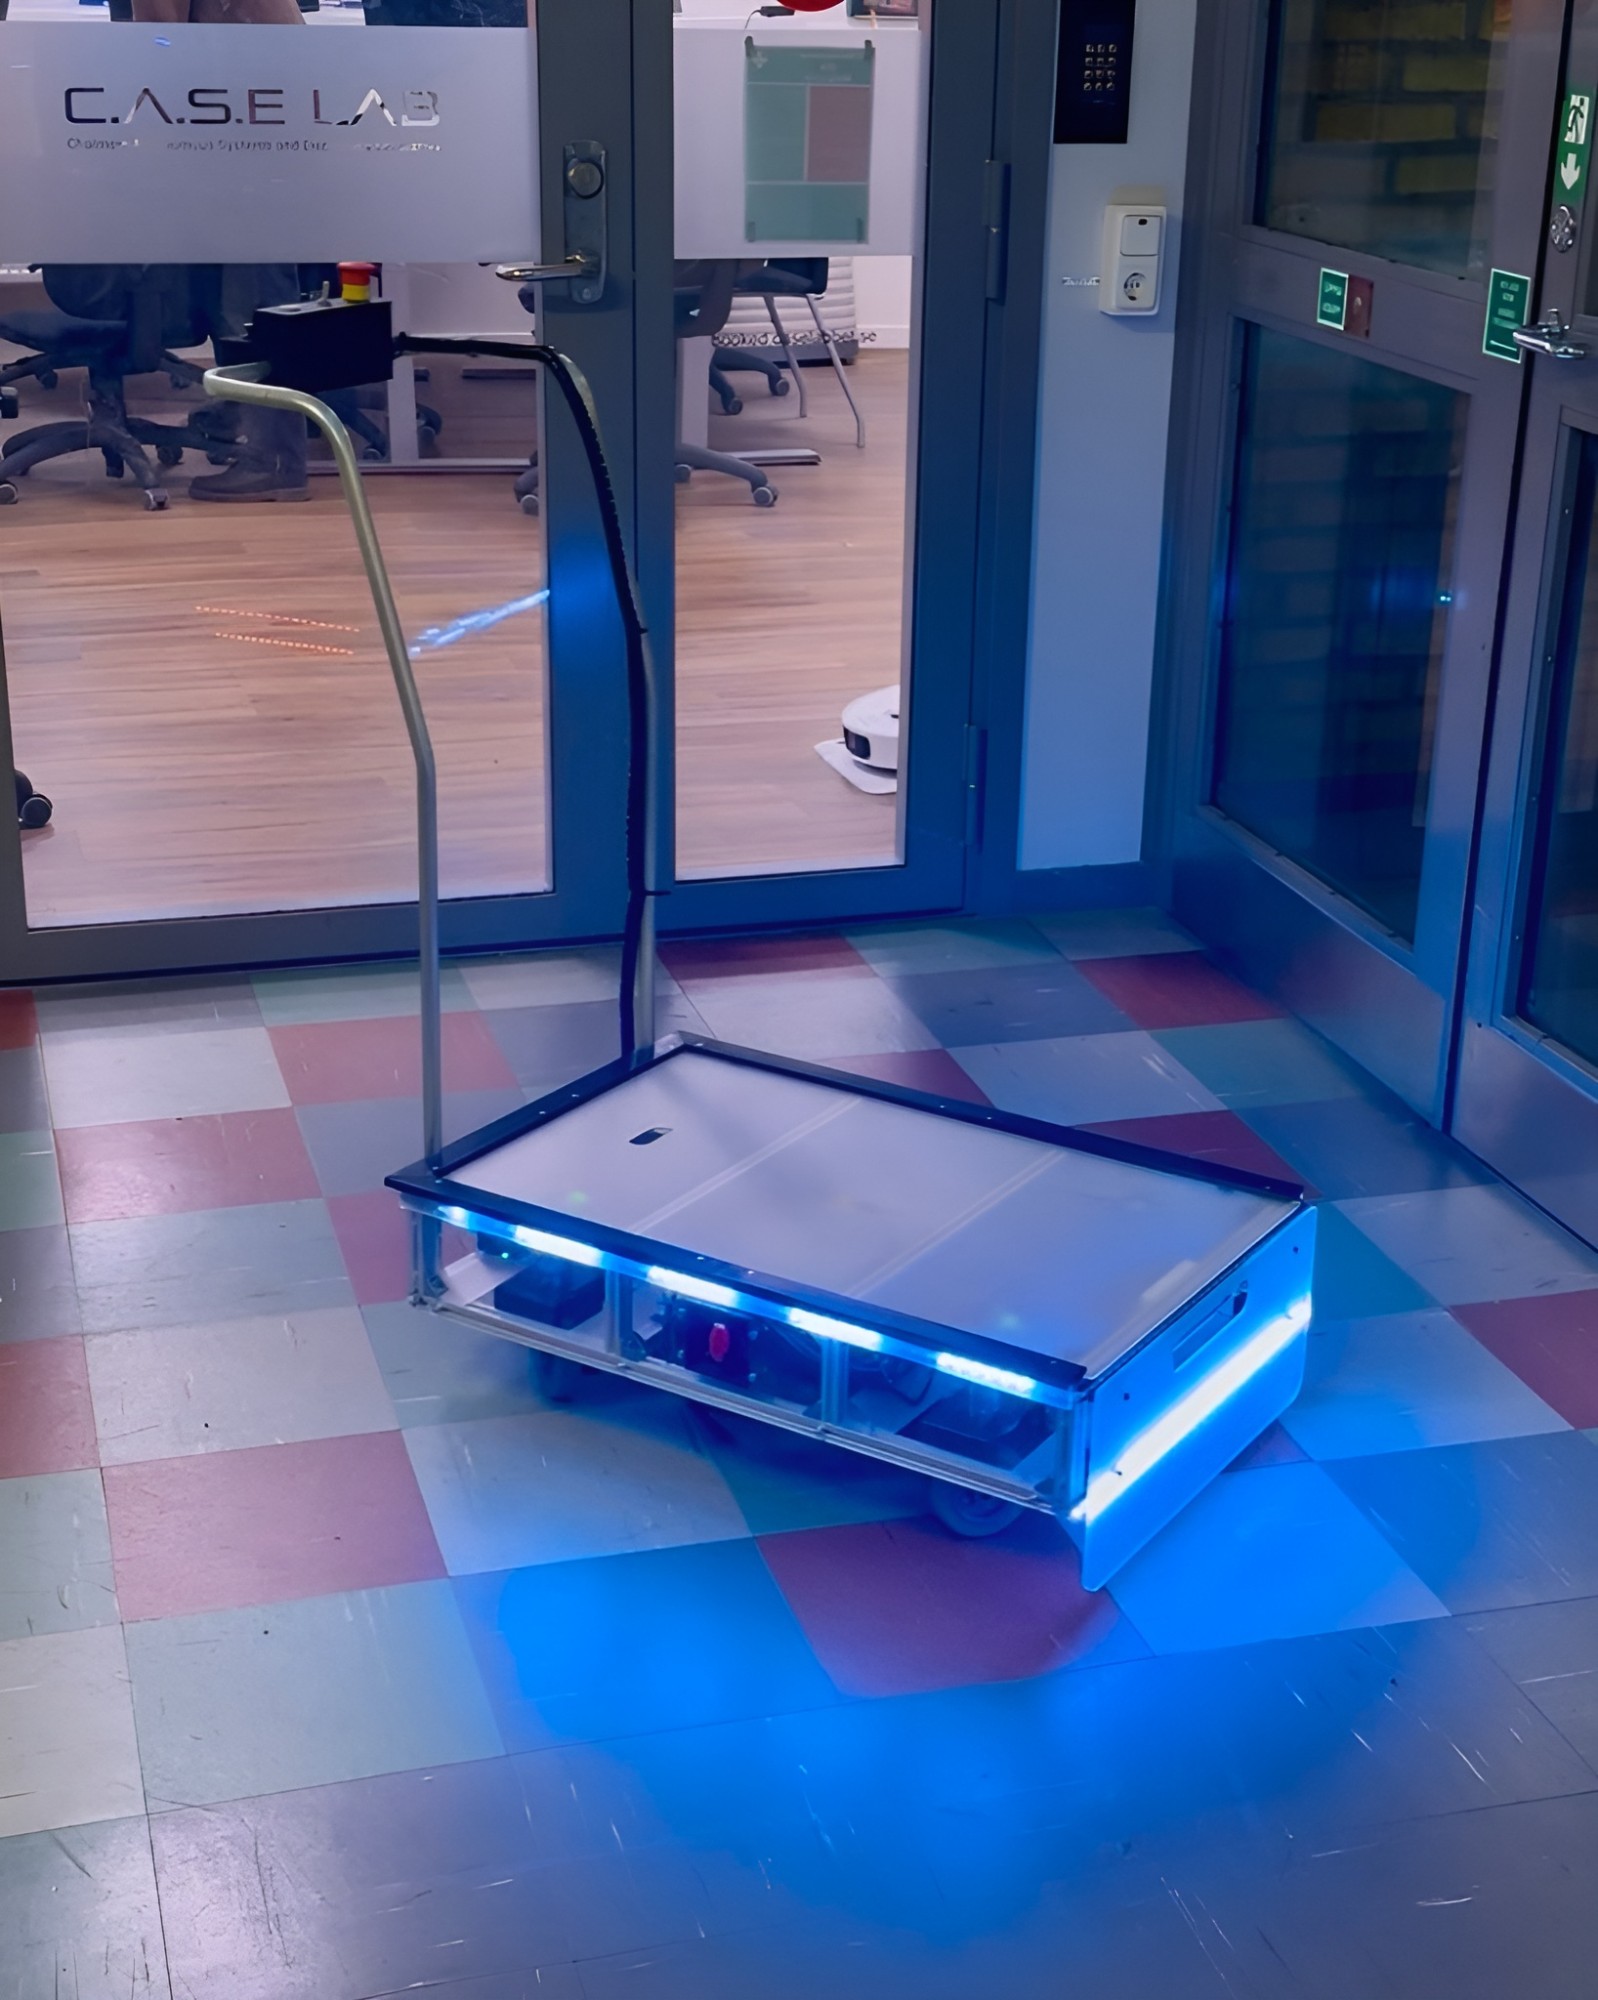
↑ The robot outside the CASE lab
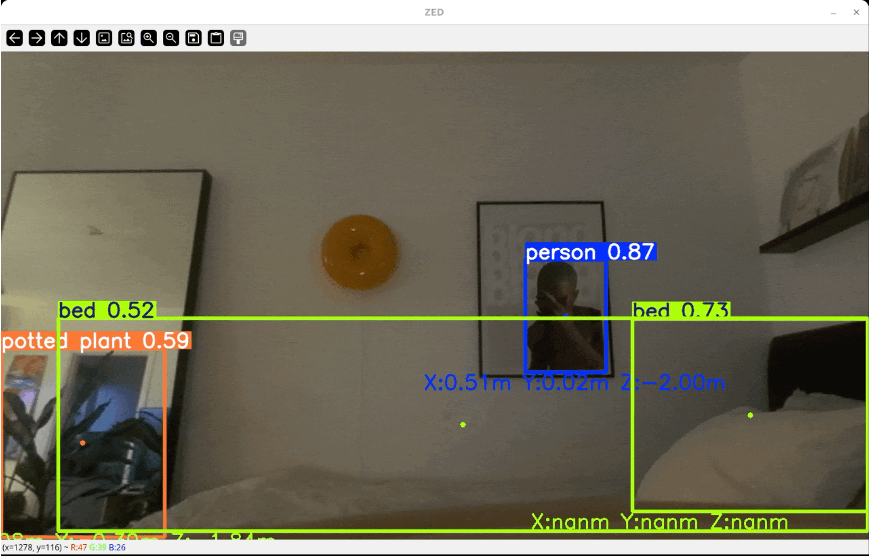
↑ ZED stereo camera detecting objects in real time
Spec sheet
The problem
A four-wheel-steer robot platform, iterated on by bachelor thesis teams over several years, was unstable and could only be driven with joysticks on its handle — and only on a lab power supply.
What I did
- 01Six of us, split into a hardware and a software group — I was in software.
- 02Rebuilt the wheel modules for a mechanically stable robot, with an FEM-checked chassis, and got it running on battery power.
- 03Wireless driving with a DualShock 4 controller, with four steering modes: front-wheel (2WS) Ackermann, four-wheel (4WS) Ackermann, crab steering and rotation on the spot.
- 04An intent system of lights — brake lights, turn signals and acceleration/deceleration animations — to show people around it what it's about to do.
- 05Groundwork for autonomy: ZED stereo-camera object detection, SLAM-based positioning and a simulated path-follower — working on their own, not yet integrated with the drive control.
Result
A stable robot that passed five of six manoeuvring tests — including parallel parking by crabbing sideways into a pocket and a slalom — and carried 500 N on top of its own 300 N weight with no change in steering or speed.
Steering modes
0
Manoeuvre tests passed
0 / 6
Payload
0 N
Tags
MechatronicsControlArduinoComputer visionCADFEM
Next / Project 02
Keeping a fire truck upright →