Project 04 / Computer vision / 2026 / TME180 · ongoing
Crash videos → driving simulator
Turning real dashcam crashes into reproducible scenarios for testing self-driving cars.
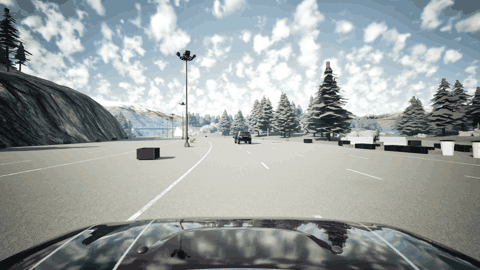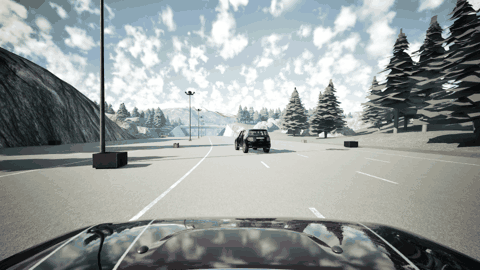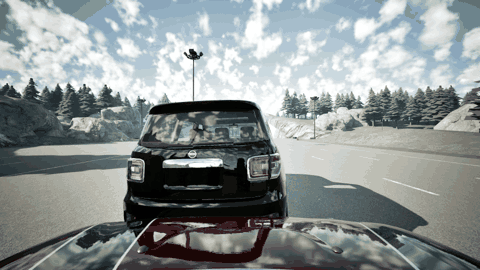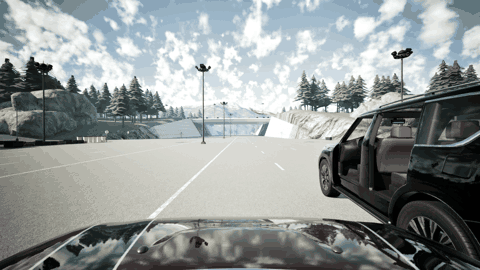
↑ A real cut-in, replayed in CARLA
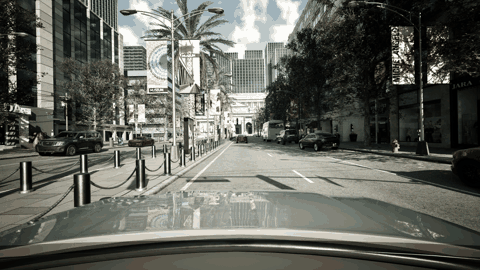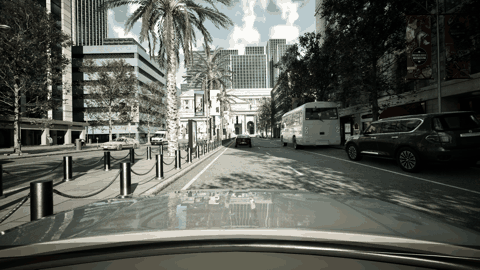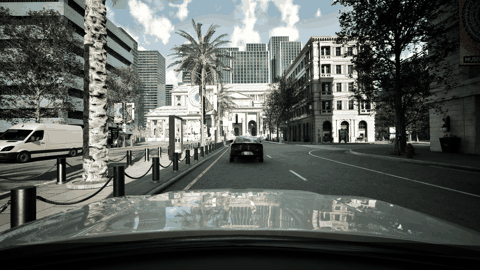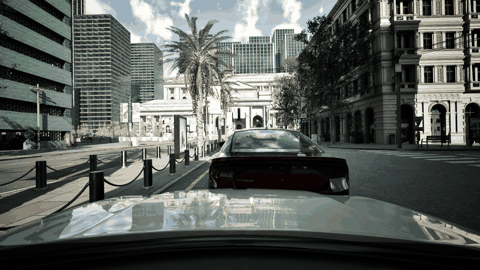
↑ City boulevard with oncoming traffic
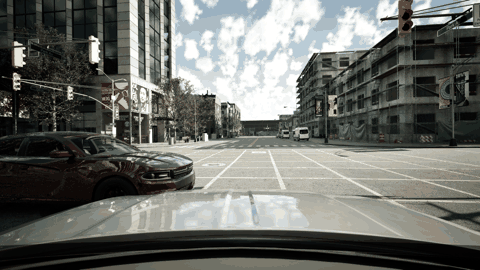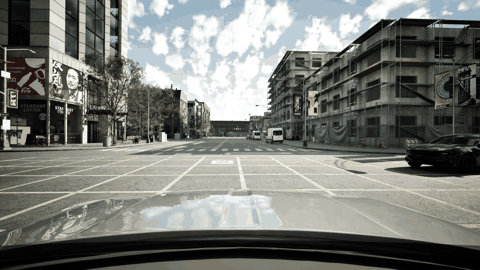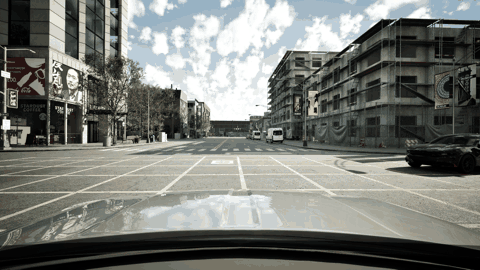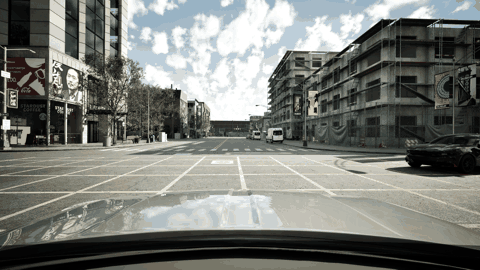
↑ Crossing traffic at an urban intersection
Spec sheet
The problem
Real crashes are rare and unrepeatable. Self-driving cars need to be tested against them anyway.
What I did
- 01Team of four, within an industry consortium. I own the metric reconstruction — pixels to metres with a flat-road camera model.
- 02Lane-marking calibration validated against national road standards, plus a depth-error model.
- 03Per-frame distance estimates for tracked vehicles feed parameterised OpenSCENARIO scenarios for CARLA.
Tags
Computer visionPythonCARLAOpenSCENARIO
Next / Project 05
Little 3D prints →